 CASCADE
4D radar with a compact architecture for object detection and tracking
A prototype built on TI's single-chip AWR2944P radar and the DCA1000EVM raw-data capture module. The radar "sees" through darkness, fog and smoke where optics and lidar fail — making it suitable for autonomous platforms, perimeter security and search-and-rescue missions.
Microsecond-long 76–81 GHz chirps pass through rain, dust and darkness, measuring range, angle and velocity simultaneously. The AWR2944P combines a C66x DSP, an Arm Cortex-R5F and a hardware accelerator (HWA) on a single chip, so signal processing happens right on the board, and its compact form factor suits wide-angle coverage on mobile platforms.
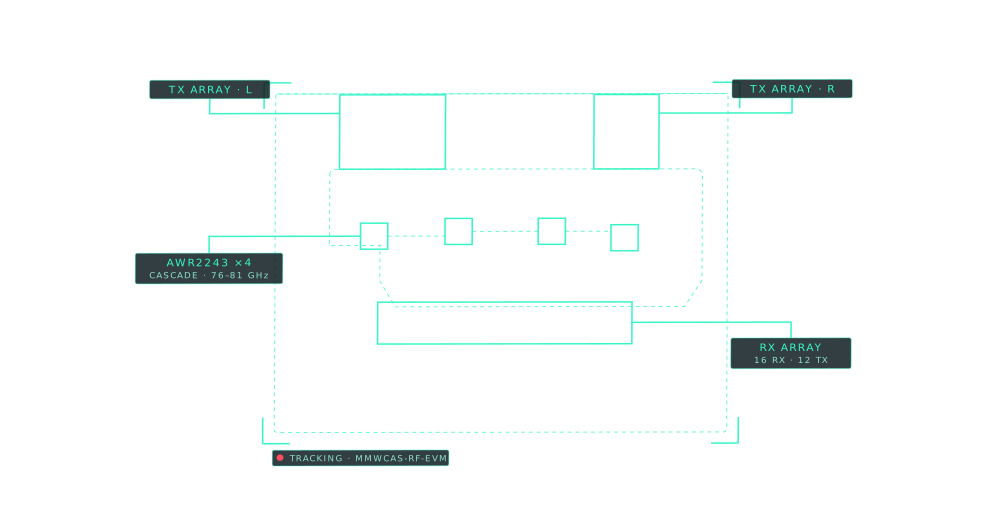
Hardware platform
1 × AWR2944P, 76–81 GHz
Radar modulecompact wide-angle surveillance radar
Detection range and cost
Based on TI dataEstimated detection range for different object types and the approximate cost of the prototype boards.
From chirp to object coordinates
Chirp transmission
Antennas on the board form a frequency-modulated 76–81 GHz signal aimed at the object within a 120° azimuth sector.
Signal reception
The AWR2944P chip, with 4 TX/4 RX, receives the reflected signal across a wide field of view.
DSP capture
The DCA1000EVM captures raw ADC data while the on-chip DSP C66x and HWA process the signal on the board itself.
Object data output
Range, angle and velocity of objects are sent over CAN-FD, Ethernet or to the host system.
From evaluation board to a working prototype
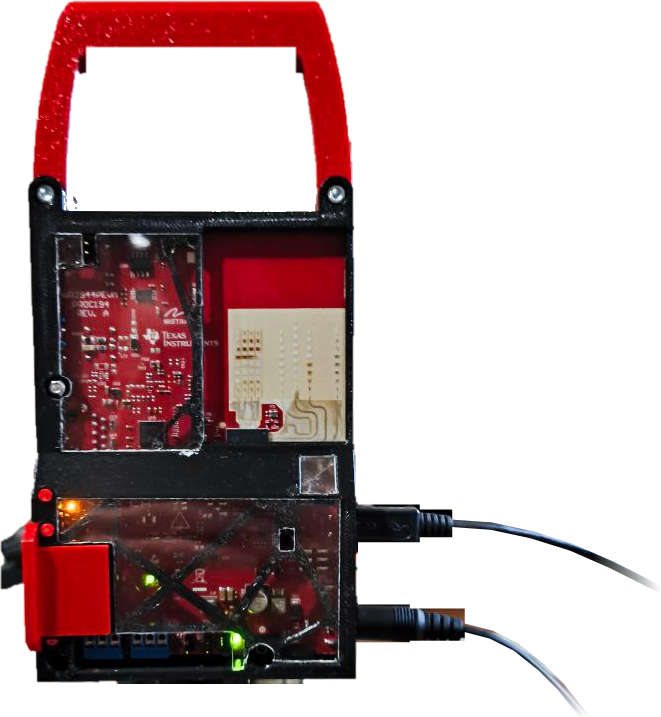
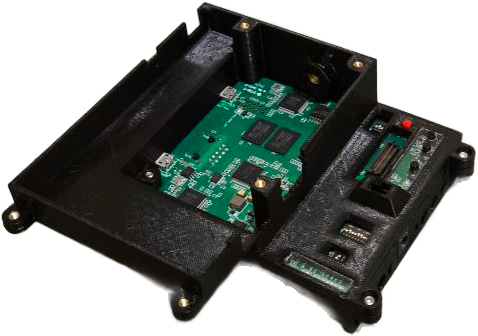
An FMCW Image Radar assembled into a working rig, controlling a rotating platform with two optical channels based on AI object recognition via a Hailo hardware accelerator for real-time operation.
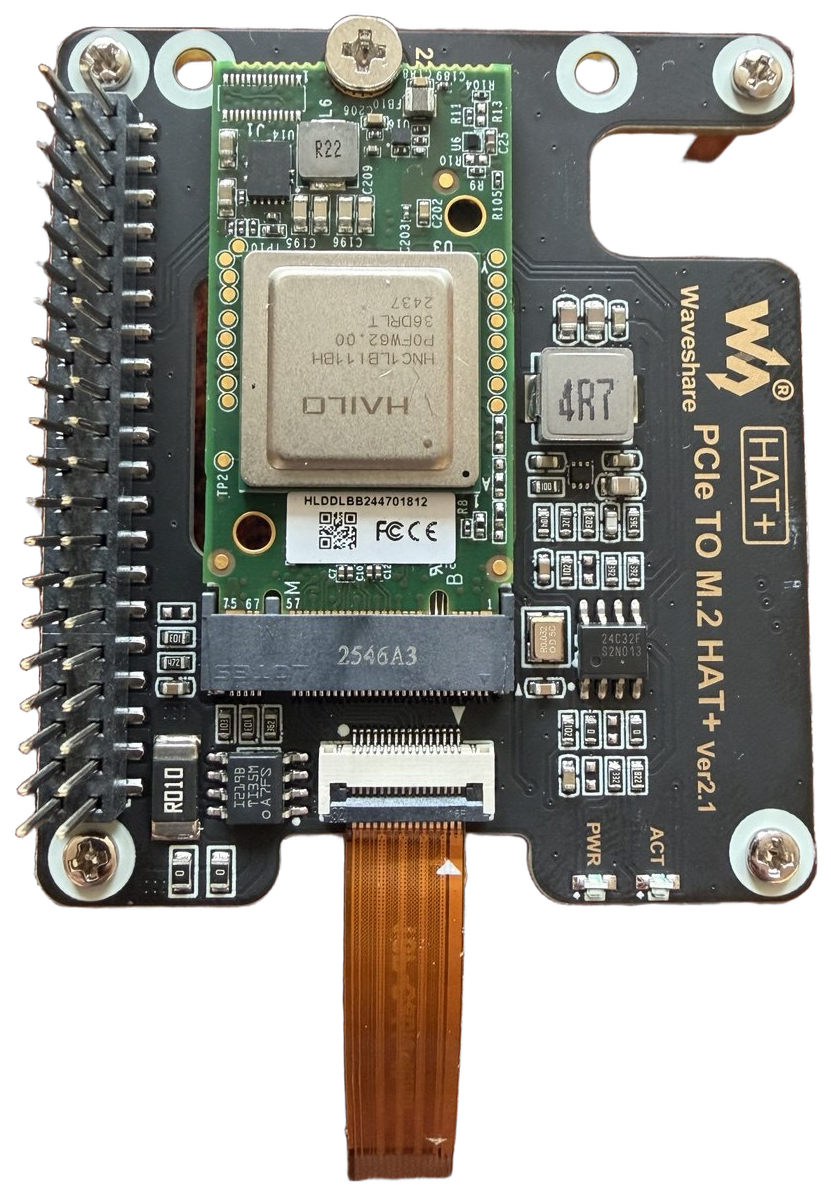
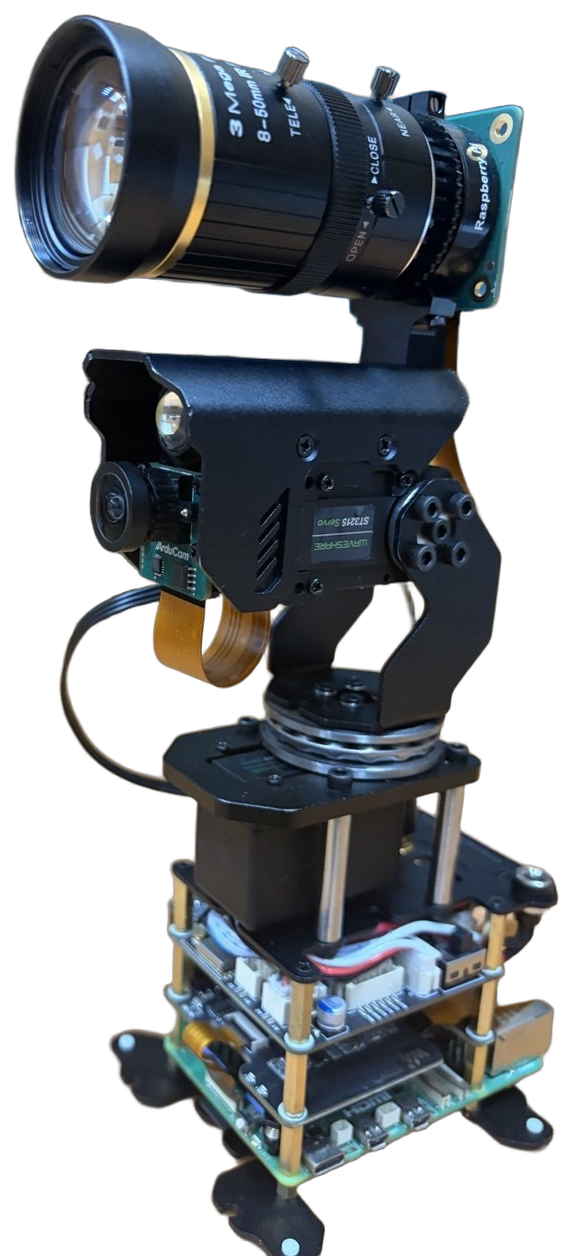
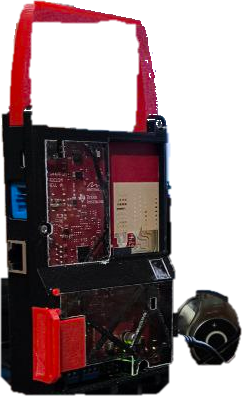
Camera and radar — in sync
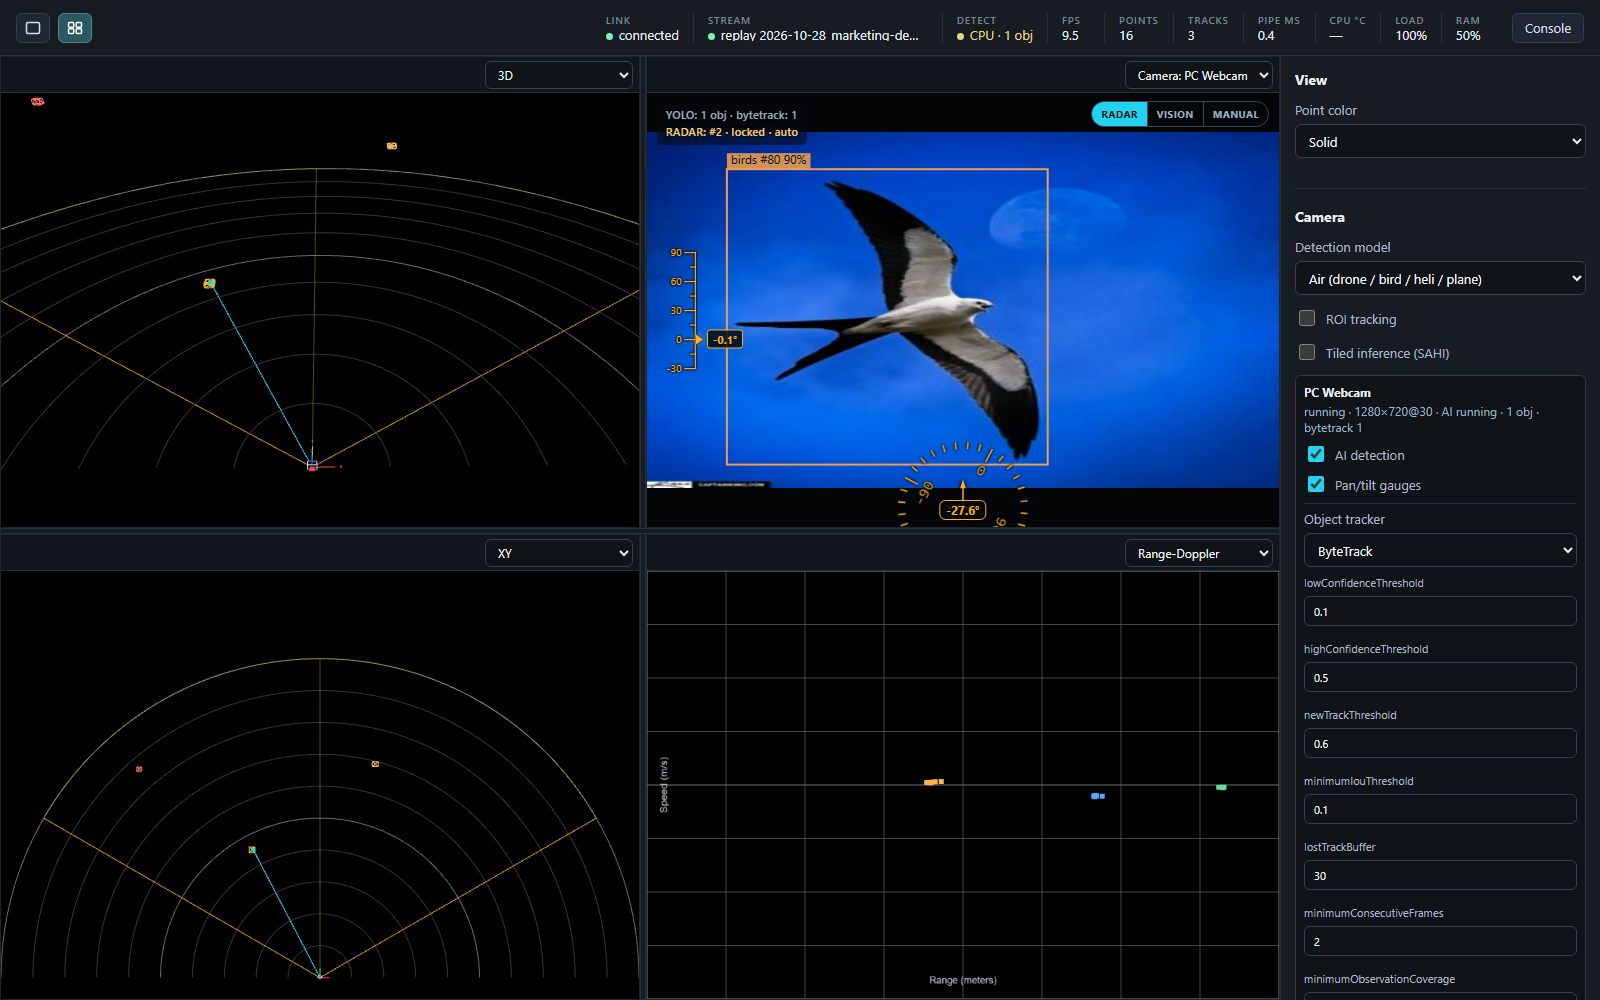
The first video is a synchronized capture of the camera feed and the radar's point cloud (range-azimuth) in nighttime city traffic: the radar keeps a solid lock on objects where oncoming headlights blind the camera. The second is a recording of the live 3D point-cloud viewer, showing the same data in real time and space.
Watch the project videos
Short videos about CASCADE: concept, demos and real-world use cases.
 Two Silent Threats
 CASCADE 4D Imaging Radar | Sees Through Smoke, Fog & Darkness
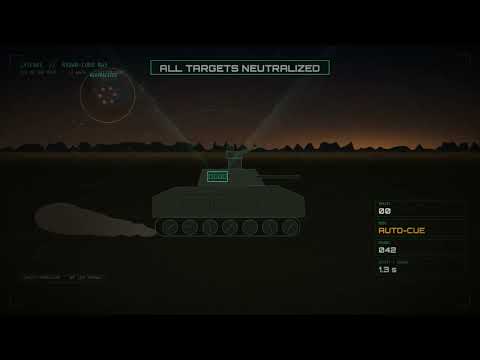 Radar-Cued Defense
 CASCADE 3D Simulation | Protection That Sees First
 CASCADE Signal Path
 CASCADE X-Ray
Two Silent Threats
CASCADE 4D Imaging Radar | Sees Through Smoke, Fog & Darkness
Radar-Cued Defense
CASCADE 3D Simulation | Protection That Sees First
CASCADE Signal Path
CASCADE X-Ray
Use cases
Autonomous ground and aerial platforms
Obstacle detection and object tracking regardless of lighting or weather.
Perimeter security & monitoring
Detecting movement along a border or security perimeter at ranges up to 220 m.
Search and rescue operations
Finding people in smoke, darkness or dense vegetation where optics fail.
Industrial & agricultural monitoring
Tracking machinery and objects across open sites and fields.
Team
Who supports the project
Join the trials
Leave your contact details if you'd like to take part in the team's trials or help with development.
Want project details or a collaboration — get in touch
SEES THROUGH DARKNESS. DETECTS FIRST. REACTS FASTER.
A compact 4D radar built on TI's AWR2944P for detecting and tracking objects through darkness, fog and smoke.
 CASCADE
A cascaded 4D radar built on TI's AWR2243/AWR2944P for detecting and tracking objects through darkness, fog and smoke.